Description of the lrTorqueLimitFactor input
The input is mainly useful for the commissioning phase if the system parameters are completely unknown.
In case of unknown system parameters, it is sensible to first limit the feedforward control to e.g. 10 % - 25 % of the rated torque.
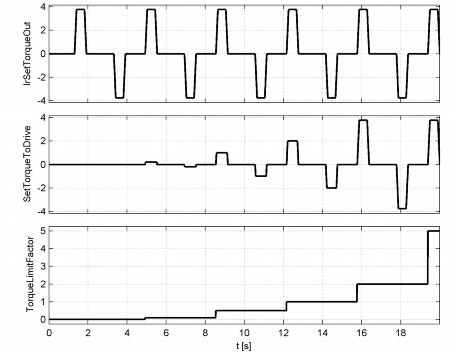
The following example shows the curve
-
of the feedforward control torque ( lrSetTorqueOut) and
-
the SetTorqueToDrive setpoint torque transmitted to the axis during a continuous movement.
The signal at the lrTorqueLimitFactor input was increased stepwise in this process:
|