Description of the lrTorqueRateLimit input
This input limits the maximum change rate of the feedforward control torque to not write any torque jumps to the drive.
Torque jumps in the calculated torque may occur if the erratic parameter changes occur at the module inputs during operation.
The limitation of the maximum change rate of the feedforward control torque is recommendable in case of erratic parameter changes during operation.
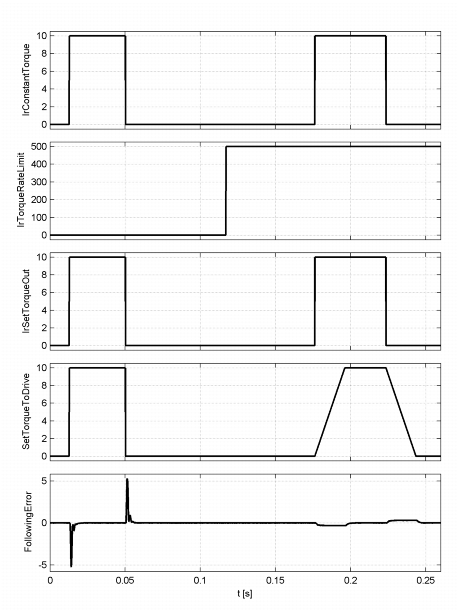
The following example shows the curve
-
of the feedforward control torque ( lrSetTorqueOut ),
-
of the ( SetTorqueToDrive) setpoint torque transmitted to the axis,
-
of the erratic change in the constant torque at standstill ( lrConstantTorque ) and
-
the following error response of the drive ( FollowingError ):
|