This FB serves to establish a position synchronism between master and slave axis.
- For clutching to the master axis, the slave axis carries out a compensating movement.
- Various modes are available for the clutch-in process.
- A shift of the synchronous positions of the master and slave serves to apply an offset.
- A gearbox factor can be defined between master and slave axis.
- Only the slave axis is moved with this FB, not the master axis.
|
|
|
|
MC_GearInPos |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
AXIS_REF |
- |
|
master |
StartSync |
|
- |
BOOL |
|
AXIS_REF |
- |
|
Slave |
InSync |
|
- |
BOOL |
|
BOOL |
- |
|
Execute |
Busy |
|
- |
BOOL |
|
INT |
- |
|
RatioNumerator |
Active |
|
- |
BOOL |
|
UINT |
- |
|
RatioDenominator |
CommandAborted |
|
- |
BOOL |
|
MC_SOURCE |
- |
|
MasterValueSource |
Error |
|
- |
BOOL |
|
LREAL |
- |
|
MasterSyncPosition |
ErrorID |
|
- |
L_IE1P_Error |
|
LREAL |
- |
|
SlaveSyncPosition |
|
|
|
|
|
MC_SYNC_MODE |
- |
|
SyncMode |
|
|
|
|
|
LREAL |
- |
|
MasterStartDistance |
|
|
|
|
|
MC_BUFFER_MODE |
- |
|
BufferMode |
|
|
|
|
|
|
|
|
|
|
|
|
|
Inputs
|
RatioDenominator UINT |
||
|
MasterValueSource |
Source of relevant data for the master axis:
|
|
|
MasterSyncPosition LREAL |
Position of the master axis where the clutch-in process ends and the master and slave axis are synchronised. |
|
|
SlaveSyncPosition LREAL |
Position of the slave axis where the clutch-in process ends and the master and slave axis are synchronised. |
|
|
SyncMode |
Mode for the clutch-in process:
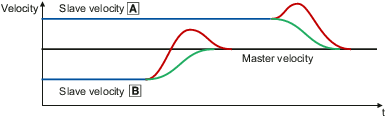
In the mcSlowDown setting the clutch-in distance is calculated internally in the FB: MasterStartDistanceIntern:= 2.0 * ABS(SlaveSyncPosition - ActSlavePosition)
The selection via the input MasterStartDistance is not evaluated. That way, the clutch-in speed of the slave will not be greater than the master speed. |
|
|
MasterStartDistance LREAL |
Distance to MasterSyncPosition for the start of synchronisation
Note: In the SyncMode = mcSlowDown setting the input MasterStartDistance is not read in. |
|
|
BufferMode |
Mode for processing successive motion commands Note: Only the mcBuffered and mcAborting buffer modes are supported. |
|


 BufferMode
Outputs
|
Name Data type |
Value/meaning |
|
|---|---|---|
|
StartSync BOOL |
TRUE |
Synchronisation starts. The master axis has passed through the MasterSyncPosition position minus the MasterStartDistance in the correct direction. |
|
InSync BOOL |
TRUE |
The slave axis is coupled to the master axis with the set gearbox ratio, both axes are now running synchronously in terms of position. |
|
Busy BOOL |
TRUE |
Processing is running. |
|
Active BOOL |
TRUE |
The command of the FB is currently executed.
|
|
CommandAborted BOOL |
TRUE |
The command was aborted by another FB.
|
|
Error BOOL |
TRUE |
An error has occurred. For details see ErrorID .
|
|
ErrorID |
If Error = TRUE: Error number for the error that has occurred.
|
|