Positioning
Target position monitoring (status "axis in target")
Target position monitoring detects whether the axis is in the symmetrical target position window (subindex 131 ) once the settling time (subindex 130 ) has elapsed.
- The information that the axis is in the target position window is provided at the FB MC_ReadAxisInfo and FB L_MC1P_AxisBasicControl via the xInPosition output.
- The xInPosition output is reset if
- the actual position leaves the target position window,
- a new motion task is started,
- an MC_Stop or MC_Halt is triggered,
- enable is revoked from the axis, or
- the home position is reset.
Window - target position reached (subindex 130)
|
|
|||||||||||
|
Symmetrical position window for target position monitoring
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Unit |
2147483647 |
0.0 unit |
||||||||
|
|
FLOAT_64 |
||||||||||


Time - target position reached (subindex 131)
|
|
|||||||||||
|
Dwell time for target position monitoring |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
s |
2147483647 |
0.0 s |
||||||||
|
|
FLOAT_64 |
||||||||||
Standstill detection
The standstill detection identifies whether the axis is at standstill.
For this purpose, the following two signals are provided:
- xStandstillSetVelocity
- xStandstillActVelocity
The information is provided at the FBs L_MC1P_AxisBasicControl and MC_ReadMotionState .
Window - standstill detection (subindex 132)
|
|
|||||||||||
|
If the current speed is within the parameterised window, the xStandstillActVelocity message is set to TRUE. |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Unit/s |
2147483647 |
0.0 Unit/s |
||||||||
|
|
FLOAT_64 |
||||||||||
Setpoint/actual value adjustment in the case of controller inhibit
Via the setting in subindex 136 or 137 , the automatic adjustment between the setpoint and actual position in the case of inverter disable can be controlled using a position window (separately adjustable for positive and negative deviation).
If the distance between the last setpoint position before inverter disable and the current actual position is smaller than the value parameterised in subindex 136 or 137 , the setpoint position maintains its last value. An adjustment with the actual position is only carried out when this window is exited.
If subindex 136 or 137 is set to 0 units, the setpoint position is always set = actual position by default in the case of an inverter disable.
Pos. tol. window SetPos=ActPos (subindex 136)
|
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Unit |
2147483647 |
0.0 unit |
||||||||
|
|
FLOAT_64 |
||||||||||
Neg. tol. window SetPos=ActPos (subindex 137)
|
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Unit |
2147483647 |
0.0 unit |
||||||||
|
|
FLOAT_64 |
||||||||||

|
Note!
The set limit value in subindex 136 and 137 should not be set greater than the drift of the actual position at drive standstill plus a safety margin, if required. Otherwise, the position controller executes an abrupt compensation when the controller inhibit has been deactivated, due to the system deviation that is pending in this state! |
Tolerance zone / blocking zone for modulo positioning
Tolerance zone
In the Modulo system, a tolerance window can be defined for absolute positioning modes in subindex 135 . The tolerance window depends on the mode applied to the mcDirection input:
- Mode "mcPositiveDirection" / "mcNegativeDirection"
- Mode "mcPositiveCycle" / "mcNegativeCycle"
Blocking zone
If the blocking zone is set too large, the axis may travel in the opposite direction!
Target positions outside of the blocking zone are approached with the selected direction select.
The blocking zone is internally limited to half the cycle.
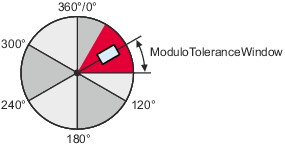
 [4-17] Definition of the blocking zone
Tolerance window - modulo positioning (subindex 135)
|
|
|||||||||||
|
Blocking zone for absolute positioning in a modulo system |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Unit |
2147483647 |
0.0 unit |
||||||||
|
|
FLOAT_64 |
||||||||||