Parameter identification with FB L_MC4P_DynamicParIdent
FB L_MC4P_DynamicParIdent can be used to determine the dynamic parameters of an axes group that are required for a torque feedforward control defined in FB L_MC4P_GroupTorquePreControl . This involves assigning an internally calculated identification trajectory (path curve) to the axes group and identifying the parameters during this motion.
In the course of this, not all mechanical variables can be identified independently of each other. For example, this issue affects the end effector and tool mass, which can only be estimated as a total amount when the tool is mounted. That is why parameters called "minimal parameters" are estimated within the identification FB.
Preconditions for identification
- Robots, motors and gearboxes must be at operating temperature.
- The controllers (position and speed controllers) must be aligned.
- For good identification, the stimulation trajectory must be configured to allow the largest possible workspace for the robot.
- Positions, speeds and accelerations must be in the size of productive operation.
- The axis torque must be able to reach at least 50% of the rated drive torque during identification.
- The following error that occurs without torque feedforward control must not exceed 400% of the required following error.
- The torque must not be too noisy (<10% of M Rated ).
- The torque must not exhibit strong vibrations (<10% of M Rated ).
- The setpoint filter of the drives (FB L_MC1P_AverageFilterSetValues ) should be switched off or, if absolutely necessary, configured with the minimum possible filter depth.
- The measurement noise of the actual velocity and the actual acceleration should be minimised.
- The override of the axes group must be at least 0.8 (= 80%).
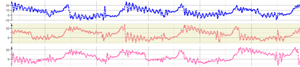
Example for excessive vibration of the torque profile; no identification is possible with this signal.
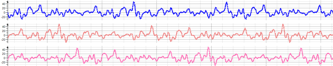
Example for a good torque profile; identification is possible with this signal.
Run identification
If the above conditions are fulfilled, identification of the dynamic parameters can be started with FB L_MC4P_DynamicParIdent .
Verifying identification results
The following options are available for verifying the results:
- Checking the results using a quality criterion
- Checking the results with a rough estimate:

|
Note!
Certain system parameters may only have a very minor influence on the motor torque compared to other variables. An example of this is a drive system with strong friction which only travels at a low rate of acceleration. In this case, the mass inertia of the axis barely has any effect on the motor torques and cannot be estimated reliably. If such effects occur, the identified minimal parameters can deviate from the theoretically calculated comparison values. |
- Checking the results with a torque comparison:
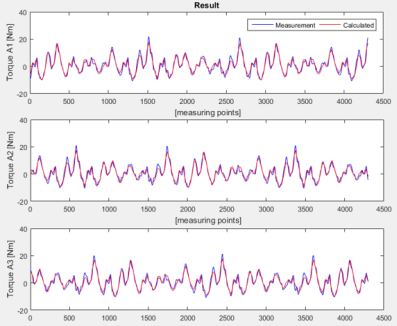
Good correlation between the calculated torque (red) and the actual torque (blue).
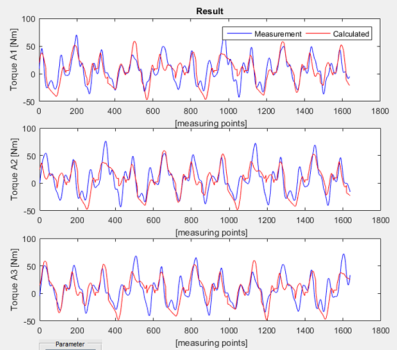
Inadequate correlation between the calculated torque (red) and the actual torque (blue).