State machine
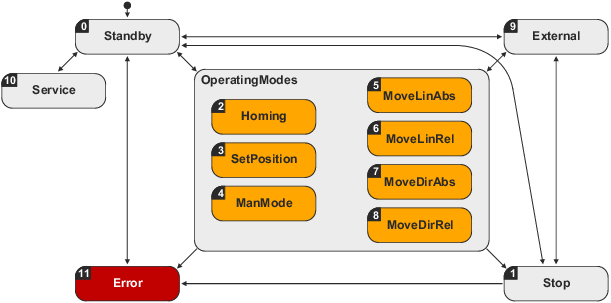
The following state diagram defines the behaviour of the FB.
- Only one state is active at any particular time.
- A changeover from one state to another state takes place if the condition for the transition between them has been fulfilled.
- The numbers correspond to the values of the ENUMS L_MC4P_AGBC_State .
|
State diagram

|

|
|---|---|
|
Status |
Description |
|
Standby |
The axes group is in the axes group state "GroupStandby" or "GroupDisabled". |
|
Stop, |
If the xGroupStopExecute input is set to TRUE, the active coordinated motion is aborted and the axes group in the "GroupStopping" axes group state is braked to standstill. In this connection, the parameters lrPathStopDec and lrPathStopJerk saved in scPar are used.
|
|
Operating modes |
A direct change between the single operating modes is possible.
Prioritisation (if different modes are selected at the same time):
|
|
External |
A function outside the FB L_MC4P_AxesGroupBasicControl generates setpoints for the axes of the axes group (e.g. MC_MoveCircularAbsolute). |
|
Service |
An axis of the axes group is supervised via one of the lower-level L_MC1P_AxisBasicControl blocks. |
|
Error |
The axis is in the "Errorstop" axis state.
|

The individual operating modes are described in the following subsections.