|
By means of this FB, the current moment of inertia can be automatically identified. The FB takes over the drive control on request and carries out the identification process.
When the identification run has been completed successfully, the moment of inertia is output via lrMInertiaIdent .
|
|
|
|
L_TB1P_IdentMInertia |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
BOOL |
- |
|
xIdent |
xBusy |
|
- |
BOOL |
|
BOOL |
- |
|
xFollowerActive |
xDone |
|
- |
BOOL |
|
LREAL |
- |
|
lrActReelSpeedIn |
xError |
|
- |
BOOL |
|
LREAL |
- |
|
lrActTorqueIn |
eErrorID |
|
- |
L_IE1P_Error |
|
LREAL |
- |
|
lrMaxSpeedIdent |
xEnableFollower |
|
- |
BOOL |
|
LREAL |
- |
|
lrMaxTorqueIdent |
lrSetTorqueOut |
|
- |
LREAL |
|
LREAL |
- |
|
lrFilterTimeSpeed |
lrMInertiaIdent |
|
- |
LREAL |
|
LREAL |
- |
|
lrFilterTimeTorque |
|
|
|
|
|
LREAL |
- |
|
lrFilterTimeReelSpeed |
|
|
|
|
|
|
|
|
|
|
|
|
|
|
Name Data type |
Information/possible settings |
|
|---|---|---|
|
xIdent BOOL |
TRUE |
Start identification of the moment of inertia. |
|
xFollowerActive BOOL |
Interface to basic "torque follower" function |
|
|
lrActReelSpeedIn LREAL |
Current speed of the motor shaft (actual speed value)
|
|
|
lrActTorqueIn LREAL |
Current torque (actual torque value)
|
|
|
lrMaxSpeedIdent LREAL |
Maximum speed for the identification of the moment of inertia
|
|
|
lrMaxTorqueIdent LREAL |
Maximum torque for the identification of the moment of inertia
|
|
|
lrFilterTimeSpeed LREAL |
Filter time constant for the actual speed value
|
|
|
lrFilterTimeTorque LREAL |
Filter time constant for the actual torque value
|
|
|
lrFilterTimeReelSpeed LREAL |
Filter time constant for the speed setpoint
|
|
|
Name Data type |
Value/meaning |
|
|---|---|---|
|
xBusy BOOL |
TRUE |
Identification of the moment of inertia is active. |
|
xDone BOOL |
TRUE |
Identification of the moment of inertia has been completed successfully. |
|
xError BOOL |
TRUE |
An error has occurred. For details see eErrorID . |
|
eErrorID |
If xError = TRUE: Error number for the error that has occurred.
|
|
|
xEnableFollower BOOL |
TRUE |
The basic function "Torque follower" is activated. |
|
lrSetTorqueOut LREAL |
Torque setpoint for the identification of the moment of inertia
|
|
|
lrMInertiaIdent LREAL |
Moment of inertia identified
|
|
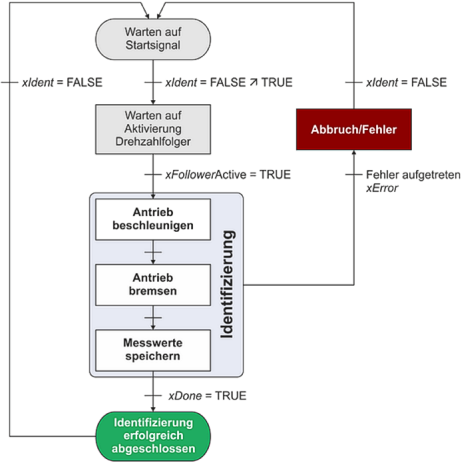
The identification is executed according to the following state machine:
|
|
State machine for the identification of the moment of inertia
If the xIdent input is reset to FALSE, the active identification process is cancelled immediately. Resetting the xFollowerActive input to FALSE also results in the immediate abort of the process.
If incremental encoders are used, it may be required to filter the actual speed value signal.
The time constant for the filter can be set via the lrFilterTimeSpeed input. A setting of '10 ms' is sufficient in most cases.