Set slip compensation
The speed of an asynchronous motor decreases as load is applied. This load-dependent speed drop
is called “slip”. The slip compensation serves to counteract the load-dependent speed loss.
is called “slip”. The slip compensation serves to counteract the load-dependent speed loss.
Preconditions
The function is only effective in the motor control type "V/f characteristic control (VFC open loop)".
In order for the function to generate the rated slip correctly the following parameters must be correctly set:
–
Rated speed
–
Rated frequency
–
Number of pole pairs (automatically calculated from Rated speed and Rated frequency)
Details
The slip compensation increases or decreases the output frequency as a response to a load change. Thus, the slip is counteracted and the speed is kept constant.
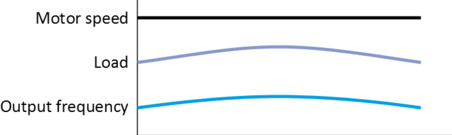
The rated slip required for the slip compensation is calculated by the inverter according to the following formula:
Rated slip [%] = (1 - (rated motor speed [rpm] / (120 * rated motor frequency [Hz] / number of poles))) * 100
Calculation example:
–
Rated motor speed = 1750 rpm
–
Rated motor frequency = 60 Hz
–
Number of poles = 2 * Number of pole pairs = 2 * 2 = 4
–
Rated slip = (1 - (1750 / (120 * 60 / 4))) * 100 = 2.77 %
The rated slip represents the reduction of the motor speed due to the motor load. At full speed and full load, the motor given in the example would rotate with 1750 rpm, which means 2.77 % below its synchronous speed of 1800 rpm. In order to compensate for this speed loss, the inverter increases the output frequency by the rated slip multiplied by the rated motor frequency. In the example, there is an increase in the output frequency at full load of 2.77 % * 60 Hz = 1.66 Hz.
In order to take into account load changes, the influence of the rated slip on the output frequency can be adapted in 0x2B09:001 (P315.01). A setting of 100 % corresponds to the rated slip of the motor in the
nominal operating point.
nominal operating point.
With reference to the example above and a setpoint frequency of 60 Hz:
–
If 0x2B09:001 (P315.01) = 100 %, the output frequency is = 61.66 Hz (60 Hz + 100 % * 1.66 Hz).
–
If 0x2B09:001 (P315.01) = 50 %, the output frequency is = 60.83 Hz (60 Hz + 50 % * 1.66 Hz).
Additionally, the filter time for the slip compensation can be adapted in 0x2B09:002 (P315.02) if required. The preset filter time is adapted to typical motors. If full load or nearly full load oscillations or instabilities occur, we recommend an increase of the filter time.
Parameter