Tuning of the motor and the speed controller
The following describes in general how to optimize the speed controller. This may be required if some parameters on the load side of the drive system have changed or have not been set yet, such as:
–
Motor moment of inertia
–
Load moment of inertia
–
Type of coupling between motor moment of inertia and load moment of inertia
Preconditions
–
All rated motor data is known and set in the inverter, either by selecting the motor from the motor catalog or manually.
 Select motor from motor catalog
Manual setting of the motor data
Select motor from motor catalog Manual setting of the motor data –
All further options for optimization have been executed before if possible.
Automatic motor identification (energized)
Automatic motor calibration (non-energized)
Automatic motor identification (energized) Automatic motor calibration (non-energized) –
Optimization is possible online or offline (with or without connected motor).
Required steps
Adapt the following parameters to your drive system using the engineering tool. Since this only changes load-dependent data, the other parameter groups do not need to be calculated again.
In the engineering tool, the speed control settings can be confirmed via the Initialise button.
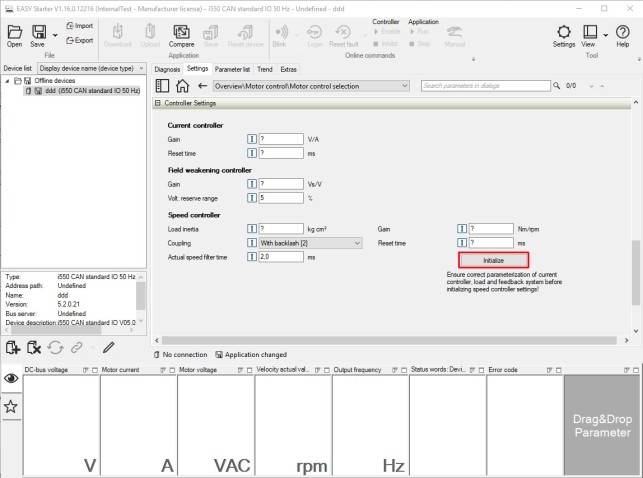
This function is not available via the keypad.
Parameter
For further details on the speed controller, see chapter "Speed controller".