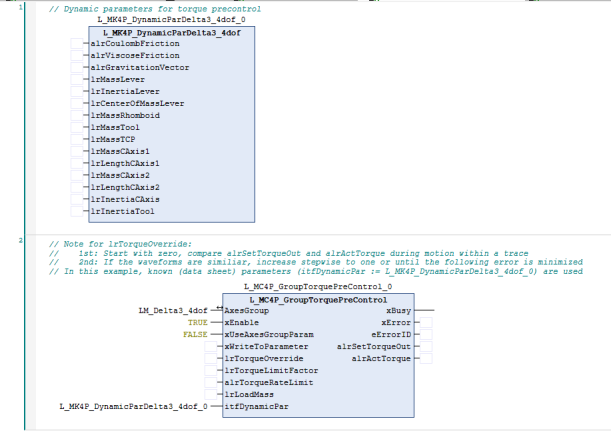
L_MK4P_DynamicParDelta3_4dof
Only for use with axes group Delta3_4dof.
(For use with axes group Delta3_3dof, see L_MK4P_DynamicParDelta3_3dof .)
FB L_MK4P_DynamicParDelta3_4dof provides axes group-specific parameters for calculating a torque feedforward control in FB L_MC4P_GroupTorquePreControl .
The FB serves as an input for the L_MC4P_GroupPreControl feedforward control module and provides the itfDynamicPar interface. This module can also define limit values for the parameter identification process of the L_MC4P_DynamicParIdent block.

|
Note!
In contrast to the L_MC4P_DynamicParIdent block, the parameters of this FB consist of user-calculated values (measured values, data sheet values, ...). They are not identified values. The kinematic parameters are read in once when the feedforward control is switched on. The parameters of the tool ( lrMassTool and lrInertiaTool ) are, however, read in cyclically. It is not necessary to call the FB in the application. |
|
|
|
|
L_MK4P_DynamicParDelta3_4dof |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
ARRAY[1..6] OF LREAL |
- |
|
alrCoulombFriction |
|
|
|
|
|
ARRAY[1..6] OF LREAL |
- |
|
alrViscoseFriction |
|
|
|
|
|
ARRAY[1..3] OF LREAL |
- |
|
alrGravitationVector |
|
|
|
|
|
LREAL |
- |
|
lrMassLever |
|
|
|
|
|
LREAL |
- |
|
lrInertiaLever |
|
|
|
|
|
LREAL |
- |
|
lrCenterOfMassLever |
|
|
|
|
|
LREAL |
- |
|
lrMassRhomboid |
|
|
|
|
|
LREAL |
- |
|
lrMassTool |
|
|
|
|
|
LREAL |
- |
|
lrMassTCP |
|
|
|
|
|
LREAL |
- |
|
lrMassCAxis1 |
|
|
|
|
|
LREAL |
- |
|
lrLengthCAxis1 |
|
|
|
|
|
LREAL |
- |
|
lrMassCAxis2 |
|
|
|
|
|
LREAL |
- |
|
lrLengthCAxis2 |
|
|
|
|
|
LREAL |
- |
|
lrInertiaCAxis |
|
|
|
|
|
LREAL |
- |
|
lrInertiaTool |
|
|
|
|
|
|
|
|
|
|
|
|
|
Inputs
|
Name Data type |
Information/possible settings |
|
|---|---|---|
|
alrCoulombFriction ARRAY [1..6] OF LREAL |
Coefficients of coulomb friction, gearbox output side [Nm] L_MK4P_DynamicParDelta3_4dof: Entries 1 ... 4 relevant |
|
|
alrViscoseFriction ARRAY [1..6] OF LREAL |
Coefficients of viscous friction, gearbox output side [Nm/(rad/s)] L_MK4P_DynamicParDelta3_4dof: Entries 1 ... 4 relevant |
|
|
alrGravitationVector ARRAY [1..3] OF LREAL |
Gravitation vector, defined in MCS [m/s 2 ] Initial values: [0, 0, -9.81] Supported parameter settings: [gx, 0, 0], [0, gy, 0], [0, 0, gz] The gravitation vector must show along one of the main axes of the MCS. |
|
|
lrMassLever LREAL |
Mass of knee lever [kg]. |
|
|
lrInertiaLever LREAL |
Moment of inertia of the knee lever with reference to the joint [kg cm 2 ]. |
|
|
lrCenterOfMassLever LREAL |
Horizontal distance of the joint to the centre of gravity of the knee lever [mm]. |
|
|
lrMassRhomboid LREAL |
Mass of parallelogram (both struts) [kg]. |
|
|
lrMassTool LREAL |
Mass of a tool or gripper [kg]. |
|
|
lrMassTCP LREAL |
Mass of end effector platform [kg]. |
|
|
lrMassCAxis1 LREAL |
Mass of upper part of the C-axis [kg]. |
|
|
lrLengthCAxis1 LREAL |
Length of upper part of the C-axis [kg]. |
|
|
lrMassCAxis2 LREAL |
Mass of lower part of the C-axis [kg]. |
|
|
lrLengthCAxis2 LREAL |
Length of lower part of the C-axis [kg]. |
|
|
lrInertiaCAxis LREAL |
Moment of inertia of the C-axis with reference to axis A4 [kg cm 2 ]. |
|
|
lrInertiaTool LREAL |
Moment of inertia of a tool or gripper with reference to axis A4 [kg cm 2 ]. |
|

 Tipp!
Further details can be found in the sections
 Torque feedforward control for reducing following errors
Determination of system parameters
(Interconnection examples)
Interconnection example