Determination of system parameters
There are three sources for determining the parameters required in FB L_MC4P_GroupTorquePreControl :
- Axes group parameters
The required friction factors and minimal parameters are read from the parameters of the axes group. Regardless of whether an FB has been created at input
itfDynamicPar
, the parameter set is evaluated from the axes group.
 Mechanical parameters
in offset 3, starting from subindex
51
.
Mechanical parameters
in offset 3, starting from subindex
51
.
- Data sheet values
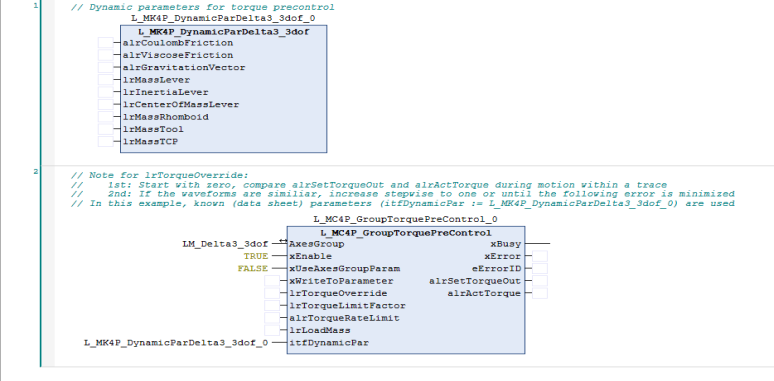
The parameters originating from a data sheet are specified here via the following FBs:
- Values identified from the L_MC4P_DynamicParIdent application FB
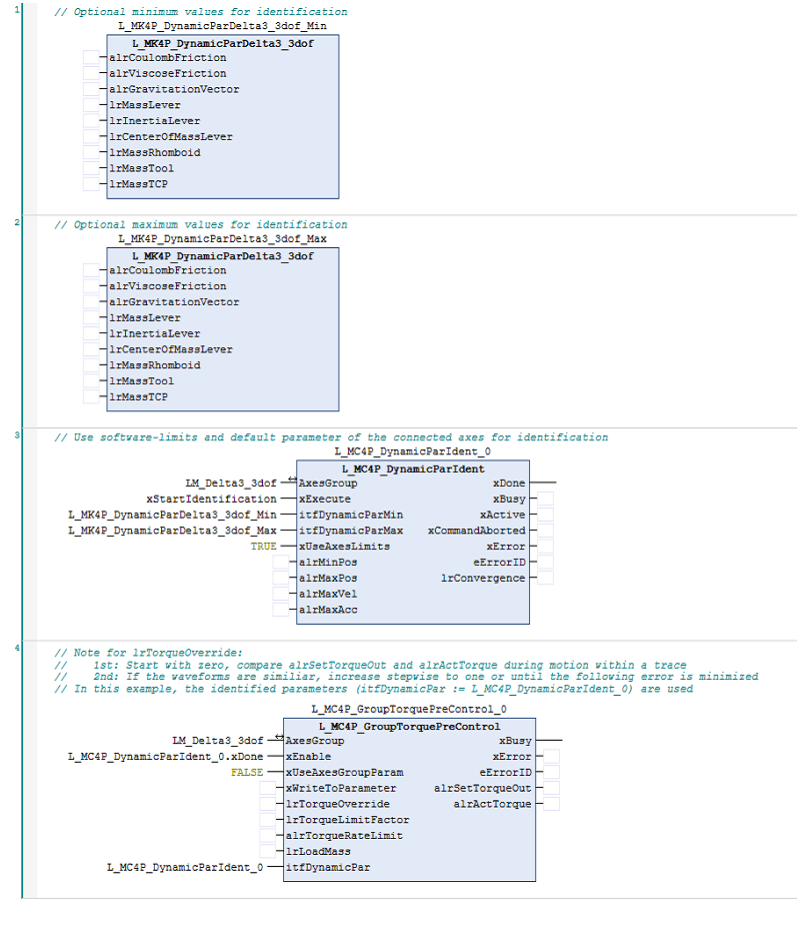
Block
L_MC4P_ DynamicParIdent
can be used to determine the dynamic parameters of an axes group that are required for a torque feedforward control. This involves assigning an internally calculated identification trajectory (path curve) to the axes group and identifying the parameters during this motion.
L_MC4P_DynamicParIdent
L_MC4P_DynamicParIdent