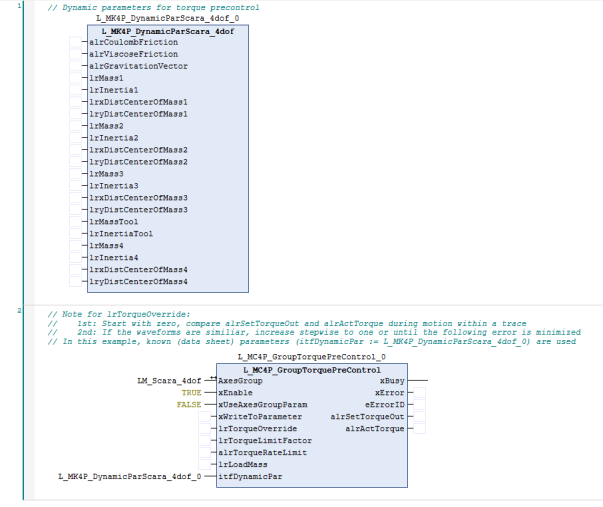
L_MK4P_DynamicParScara_4dof
Only for use with axes group Scara_4dof.
(For use with axes group Scara_3dof see L_MK4P_DynamicParScara_3dof .)
The L_MK4P_ DynamicParScara_4dof function block serves
- to set the kinematics-dependent parameters for the torque feedforward control of the Scara_4dof axis group.
- as an input for the L_MC4P_GroupPreControl function block and provides the itfDynamicPar interface.
-
to specify the limit values for parameter identification of the function block
L_MC4P_DynamicParIdent
,
see model connection in the section Determination of system parameters
.
In contrast to the function block L_MC4P_DynamicParIdent the parameters of the L_MK4P_ DynamicParScara_4dof function block are not identified values, but user-calculate values, e.g. measured values or values from a data sheet.
|
|
|
|
L_MK4P_DynamicParScara_3dof |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
ARRAY[1..6] OF LREAL |
- |
|
alrCoulombFriction |
|
|
|
|
|
ARRAY[1..6] OF LREAL |
- |
|
alrViscoseFriction |
|
|
|
|
|
ARRAY[1..3] OF LREAL |
- |
|
alrGravitationVector |
|
|
|
|
|
LREAL |
- |
|
lrMass1 |
|
|
|
|
|
LREAL |
- |
|
lrInertia1 |
|
|
|
|
|
LREAL |
- |
|
lrxDistCenterOfMass1 |
|
|
|
|
|
LREAL |
- |
|
lryDistCenterOfMass1 |
|
|
|
|
|
LREAL |
- |
|
lrMass2 |
|
|
|
|
|
LREAL |
- |
|
lrInertia2 |
|
|
|
|
|
LREAL |
- |
|
lrxDistCenterOfMass2 |
|
|
|
|
|
LREAL |
- |
|
lryDistCenterOfMass2 |
|
|
|
|
|
LREAL |
- |
|
lrMass3 |
|
|
|
|
|
LREAL |
- |
|
lrInertia3 |
|
|
|
|
|
LREAL |
- |
|
lrxDistCenterOfMass3 |
|
|
|
|
|
LREAL |
- |
|
lryDistCenterOfMass3 |
|
|
|
|
|
LREAL |
- |
|
lrMassTool |
|
|
|
|
|
LREAL |
- |
|
lrInertiaTool |
|
|
|
|
|
LREAL |
- |
|
lrMass4 |
|
|
|
|
|
LREAL |
- |
|
lrInertia4 |
|
|
|
|
|
LREAL |
- |
|
lrxDistCenterOfMass4 |
|
|
|
|
|
LREAL |
- |
|
lryDistCenterOfMass4 |
|
|
|
|
|
|
|
|
|
|
|
|
|
Inputs
|
Name Data type |
Information/possible settings |
|
|---|---|---|
|
alrCoulombFriction ARRAY [1..6] OF LREAL |
Coefficients of coulomb friction, gearbox output side [Nm] |
|
|
alrViscoseFriction ARRAY [1..6] OF LREAL |
Coefficients of viscous friction, gearbox output side [Nm/(rad/s)] |
|
|
alrGravitationVector ARRAY [1..3] OF LREAL |
Gravitation vector, defined in MCS [m/s 2 ] Initial values: [0, 0, -9.81] |
|
|
lrMass<1 ... 4> LREAL |
Mass of partial bodies 1 to 4 of the robot [kg]. |
|
|
lrInertia<1 ... 4> LREAL |
Moment of inertia of partial bodies 1 to 4 of the robot with reference to each pivot point [kg cm 2 ]. |
|
|
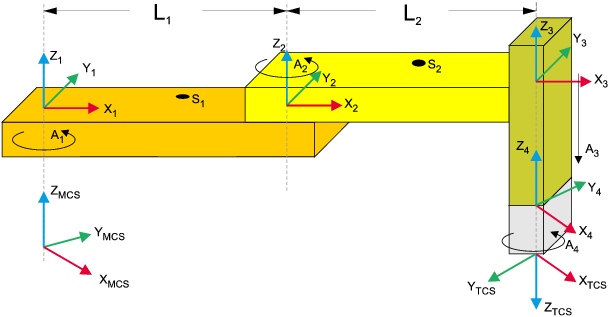
lrxDistCenterOfMass<1 ... 4> LREAL |
Distance between joint and center of gravity of each partial body in x-direction of the body coordinate system [mm],
see graphic
|
|
|
lryDistCenterOfMass<1 ... 4> LREAL |
Distance between joint and center of gravity of each partial body in y-direction of the body coordinate system [mm],
see graphic
|
|
|
lrMassTool LREAL |
Mass of a tool or gripper [kg]. |
|
|
lrInertiaTool LREAL |
Moment of inertia of a tool or gripper with reference to zTCS [kg cm 2 ]. |
|
Reference coordinate system for the parameters
|

 Tip!
Further details can be found in the sections
Torque feedforward control for reducing following errors
Determination of system parameters
(Model connections)
Interconnection example