MC_Stop
This FB serves to stop the axis in a controlled way (lead to standstill). All running motion commands are aborted. For the main part, the FB is meant for emergency stop functions and exceptional situations.
- In contrast to the MC_Halt commands, further motion commands during the ramp-down cannot be executed as it is ramped down in the " Stopping " state.
- The " Stopping " state remains active until Execute is set to TRUE or the axis is not yet at standstill.
- When Done = TRUE and Execute = FALSE, the state is changed to " Standstill ". Only now, motion commands can be executed.
|
|
|
|
MC_Stop |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
AXIS_REF |
- |
|
Axis |
Done |
|
- |
BOOL |
|
BOOL |
- |
|
Execute |
Busy |
|
- |
BOOL |
|
LREAL |
- |
|
Deceleration |
CommandAborted |
|
- |
BOOL |
|
LREAL |
- |
|
Jerk |
Error |
|
- |
BOOL |
|
|
|
|
|
ErrorID |
|
- |
L_IE1P_Error |
|
|
|
|
|
|
|
|
|
Inputs
|
Name Data type |
Information/possible settings |
|
|---|---|---|
|
Axis |
Transfer of the axis data structure |
|
|
Execute BOOL |
FALSE ä TRUE |
Lead axis to standstill. |
|
Deceleration LREAL |
Maximum deceleration for ramping down to standstill [unit/s 2 ] Special case : Deceleration = 0: The default value defined in subindex 41 is used for the acceleration. |
|
|
Jerk LREAL |
Maximum jerk for ramping down to standstill [unit/s 3 ] Special case : Jerk = 0: The default value defined in subindex 43 is used for the jerk. |
|
 Motion axes (AXIS_REF)
Outputs
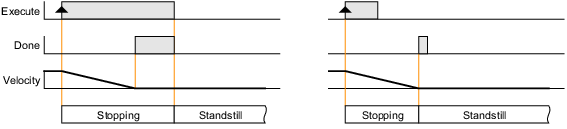
Example 1: State change from "Stopping" to "Standstill"
The following example shows the behaviour of MC_Stop in combination with the motion command MC_MoveVelocity :
-
Case
 : The axis is lead to standstill with
MC_Stop
.
-
Case
 : No motion commands are accepted as long as the
Execute
input of
MC_Stop
is set to TRUE. (In this case,
MC_MoveVelocity
reports an error.)
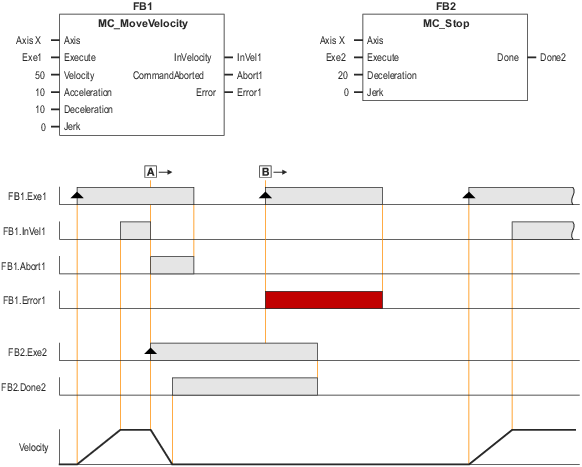
Example 2: Behaviour of MC_Stop in combination with MC_MoveVelocity