ArticulatedPLinA1_4dof
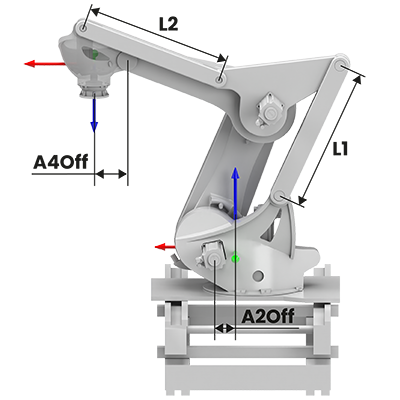
The "ArticulatedPLinA1_4dof" axes group describes a spatial articulated robot with forcibly guided horizontal end effector orientation and linear A1 axis.
|
ArticulatedPLinA1_4dof axes group: Overview / Mechanical data |
|---|
|
|
|
Axis legend: x - red y - green z - blue |
Degrees of freedom (dof)
|
Degrees of freedom (dof) |
Translation |
Rotation |
|---|---|---|
|
Drives |
A1 |
A2, A3, A4 |
|
Tool |
x, y, z |
C |
MCS position
- z-axis points upwards.
- x-axis points in the direction of the end effector.
- z-axis corresponds to the linear axis A1.
- The origin of the coordinate system is on a level with the rotary axis A2.
TCS position
-
Z axis in direction of impact of the robot
 Aligned opposite to z
MCS
.
- In zero position, x TCS and x MCS are parallel.
- The origin of the TCS lies on the drive axis A4.
Zero position of the drives
- In the zero position of all drives, the upper arm of the robot is horizontal and the end effector is at the position
- x = A2Off +A3Off + L2 + A4Off.
- z = 0
- z = L1
Parameter
A complete list of all kinematics-independent parameters can be found in the section
 Short overview of all parameters
|
Horizontal offset of axis 2 to axis 1 (A2 OFF ) |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||


|
Length of arm 1 (L1) |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||
|
Horizontal offset of axis 3 to the passive joint of arm 1 at the parallelogram (A3 OFF )
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||
|
Length of arm 2 (L2) |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||
Axis offset A4Off (index offset 3, subindex 6)
|
Horizontal offset of axis 4 to the passive joint of arm 2 at the end effector (A4 OFF ) |
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||
Mounting location A3 (index offset 3, subindex 10)
|
This parameter serves to switch over between two typical versions of kinematics ArticulatedPLinA1_4dof. |
|||||||||||
|
Selection list (Lenze setting printed in bold) |
Info |
||||||||||
|
0 |
Elbow |
If the standard value Elbow is selected, the drive motor of elbow axis A3 is mounted in the elbow joint. The illustration above corresponds to this setting. |
|||||||||
|
1 |
Shoulder |
If the value Shoulder is selected, an alternative mechanical version is used for transformation. Here, the drive motor of elbow axis A3 on the robot basis is mounted coaxially to shoulder joint A2. The movement of the motor is transmitted to arm L2 through parallel motion. |
|||||||||
|
|
UNSIGNED_8 |
||||||||||