Portal_2dof
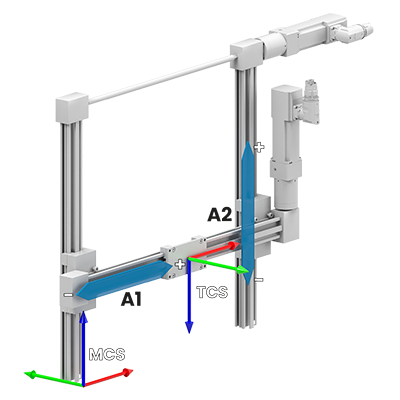
The "Portal_2dof" axes group describes a planar portal robot with two Cartesian degrees of freedom (X, Z).
|
Portal_3dof axes group: Overview / Connected drives |
|---|
|
|
|
Axis legend: x - red y - green z - blue |
Degrees of freedom (dof)
|
Degrees of freedom (dof) |
Translation |
Rotation |
|---|---|---|
|
Drives |
A1, A2 |
- |
|
Tool |
x, z |
- |
MCS position
- The x axis is congruent with the A1 axis
- The z axis is congruent with the A2 axis.
TCS position
- xTCS and xMCS are parallel.
- yTCS is aligned opposite to yMCS.
- zTCS is aligned opposite to zMCS.
- In zero position, the coordinate origins MCS and TCS are congruent.
Zero position of the drives
The zero setting of the drives defines the origin of the MCS.
Singularities
The Portal_2dof axes group has no singularity.
Parameter
A complete list of all kinematics-independent parameters can be found in the section
 Short overview of all parameters
Related topics
Traversing ranges of connected axes
Considering differential drives