Portal_4dof
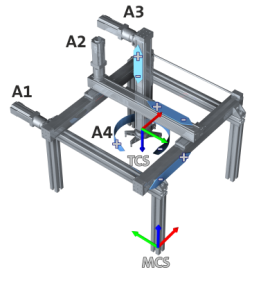
The "Portal_4dof" axes group describes a spatial portal robot with four Cartesian degrees of freedom (X, Y, Z, C).
|
Portal_4dof axes group: Overview / Connected drives |
|---|
|
|
|
Axis legend: x - red y - green z - blue |
Degrees of freedom (dof)
|
Degrees of freedom (dof) |
Translation |
Rotation |
|---|---|---|
|
Drives |
A1, A2, A3 |
A4 |
|
Tool |
x, y, z |
C |
MCS position
- The x axis is congruent with the A1 axis
- The y axis is congruent with the A2 axis.
- The z axis is congruent with the A3 axis.
- The A4 axis rotates around the positive zMCS axis, and hence in a negative sense around the zTCS axis
TCS position
- xTCS and xMCS are parallel if A4 = 0.
- yTCS ist aligned opposite to yMCS.
- zTCS is aligned opposite to zMCS.
- In zero position, the coordinate origins MCS and TCS are congruent.
Zero position of the drives
The zero setting of drives A1, A2 and A3 defines the origin of the MCS.
Singularities
The Portal_4dof axes group has no singularity.
Parameter
A complete list of all kinematics-independent parameters can be found in the section
 Short overview of all parameters
Related topics
Traversing ranges of connected axes
Considering differential drives