The position and orientation of a tool in space is described in relation to a coordinate system using coordinates. The following two conventions are available for this, which are described in more detail below:
Cartesian coordinates
A Cartesian coordinate system consists of three coordinate axes X, Y and Z that are perpendicular to each other. These axes can be used to clearly describe positions in the three-dimensional workspace.
In addition to the position, the orientation of an object (coordinate system) can also be described. Three cardan angles A, B and C around the coordinate axes X, Y and Z are used for this purpose. These three angles describe the orientation of a coordinate system through three successive rotations around X (angle A), then around the co-rotated Y' axis (angle B) and finally around the co-rotated Z'' axis (angle C).
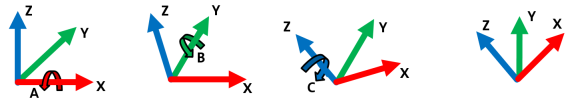
 [16-5] Coordinate axes X, Y and Z in the Cartesian coordinate system

|
Please note!
The sequence of the successive rotations can be selected via the Offset0-Subindex39 parameter. The example above describes the behaviour in the default setting 0: "x-y'-z" rotation with rotation. |
Cylinder coordinates
A position is described in cylindrical coordinates by a radius R, an angle PHI and a height H.
Firstly, R defines the distance of a point from the Z-axis of a reference system. The angle PHI rotates this point around this axis in a mathematically positive sense. Finally, the point is shifted parallel to the Z-axis by the height H. In this way, every point in the three-dimensional workspace can be uniquely described by these three coordinates.
- Cylindrical coordinates are particularly suitable for rotationally symmetrical kinematics (e.g. rotating positioning tables).
- Orientations are represented by the cardan angles A, B and C, analogue to the Cartesian coordinate system.
Function blocks for Cartesian transformations
The function blocks for Cartesian transformations provide the calculations required to define a PCS relative to the MCS and to read out the current transformation between MCS and PCS.
The enumeration type L_MC4P_CoordType, which is an element of the data structure MC_COORD_REF, is available for defining the convention (Cartesian coordinates or cylindrical coordinates) (see following section).
|
|
Please note!
Note when using 4D kinematics: If a movement is programmed using a product coordinate system (e.g. target position specified in PCS_4: MC_MoveLinearAbsolute1.CoordSystem := L_MC4P_CoordSystem.PCS_4), the z-axis of the PCS must be aligned with or against the z-axis of the WCS! See also: Special treatments for 4D kinematics |
Data structure MC_COORD_REF
The MC_COORD_REF data structure contains the coordinate transformation: