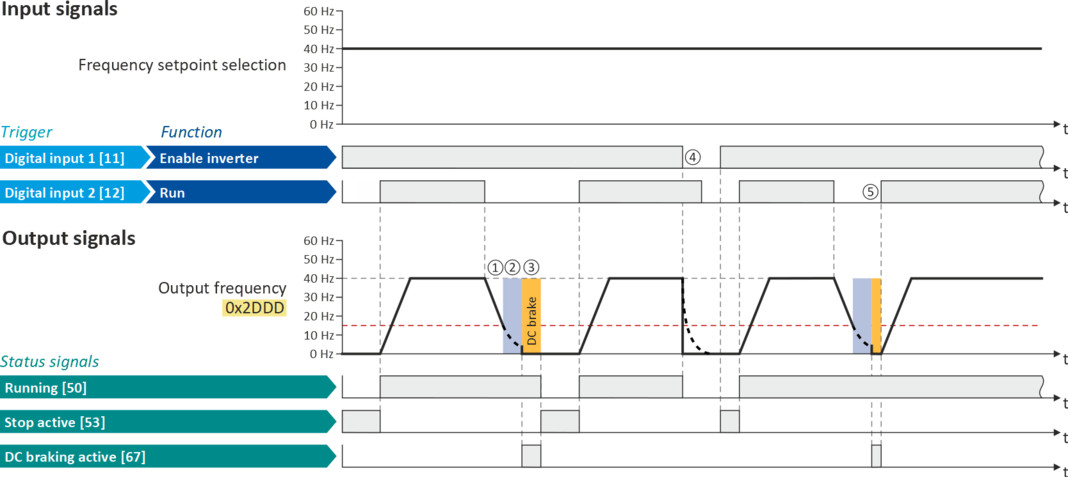
Example: Automatic DC braking when stopping the motor
In order that the DC braking is automatically active when the motor is stopped, the corresponding operating threshold must be set in 0x2B84:003 (P704.03).
–
After a stop command, the motor is first decelerated as set. Once the output frequency falls below the set operating threshold, the inverter stops the deceleration and activates DC braking.
–
DC braking is carried out with the braking current set in 0x2B84:001 (P704.01) for the hold time set in 0x2B84:002 (P704.02).
–
The exact behavior depends on the stop method set in 0x2838:003 (P203.03).
Stop method = "Standard ramp [1]"
|
Parameter
|
Name
|
Setting for this example
|
|
Enable inverter
|
Digital input 1 [11]
|
|
|
Run
|
Digital input 2 [12]
|
|
|
Reset fault
|
Not connected [0]
|
|
|
Stop method
|
Standard ramp [1]
|
|
|
Frequency control: Default setpoint source
|
Frequency preset 1 [11]
|
|
|
Frequency setpoint presets: Preset 1
|
40 Hz
|
|
|
Current
|
50%
|
|
|
Automatic hold time
|
10 s
|
|
|
Automatic operating threshold
|
15 Hz
|
|
The status signals can be assigned to digital outputs.
 Configure digital outputs |
|
|
|
|
|
①
|
With the stop method "Standard ramp [1]", the motor is first decelerated normally until the value falls below the operating threshold set in 0x2B84:003 (P704.03).
|
|
②
|
The motor coasts down for a specified time. This "demagnetizing time" serves to reduce the induced voltage.
|
|
③
|
The DC braking becomes active for the hold time set in 0x2B84:002 (P704.02).
|
|
④
|
If the inverter is disabled, the motor coasts. (DC braking is only possible if the inverter is enabled).
|
|
⑤
|
If there is a new start command within the hold time, the DC braking is cancelled. The motor is accelerated to the setpoint again.
|
Stop method = "Quick stop ramp [2]"
Same behavior as with the stop method "Standard ramp [1]", except that the motor is decelerated with the quick stop ramp instead of the standard ramp.
Stop method = "Coasting [0]"
|
Parameter
|
Name
|
Setting for this example
|
|
Enable inverter
|
Digital input 1 [11]
|
|
|
Run
|
Digital input 2 [12]
|
|
|
Stop method
|
Coasting [0]
|
|
|
Frequency control: Default setpoint source
|
Frequency preset 1 [11]
|
|
|
Frequency setpoint presets: Preset 1
|
40 Hz
|
|
|
Current
|
50%
|
|
|
Automatic hold time
|
10 s
|
|
|
Automatic operating threshold
|
15 Hz
|
|
The status signals can be assigned to digital outputs.
Configure digital outputs |
|
|
|
|
|
①
|
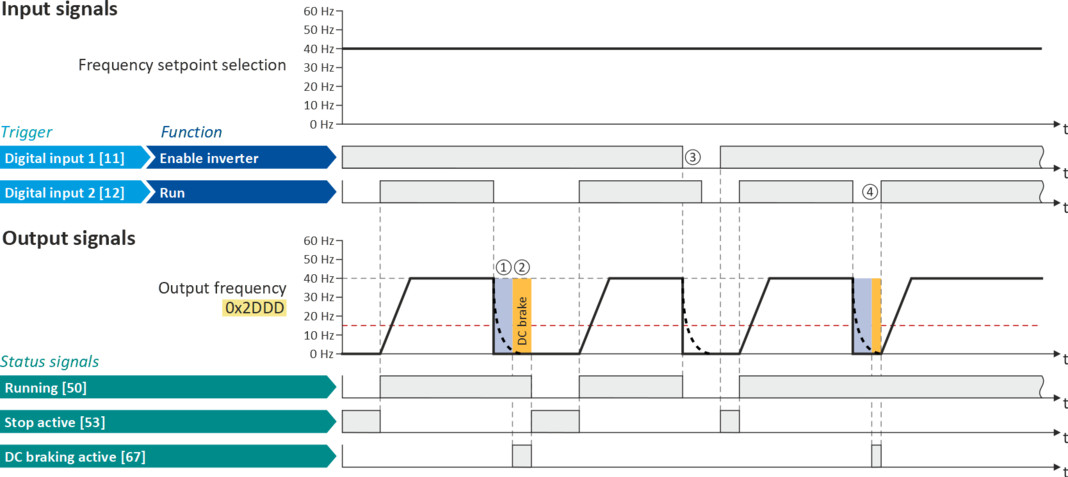
With the stop method "Coasting [0]", the motor first coasts down for a specified time. This "demagnetizing time" serves to reduce the induced voltage.
|
|
②
|
The DC braking becomes active for the hold time set in 0x2B84:002 (P704.02).
|
|
③
|
If the inverter is disabled, the motor coasts. (DC braking is only possible if the inverter is enabled).
|
|
④
|
If there is a new start command within the hold time, the DC braking is cancelled. The motor is accelerated to the setpoint again.
|