Position counter
This function counts the number of motor revolutions. The current counter content (actual position) can be output as process data value via network to implement a simple position control in a higher-level Controller.
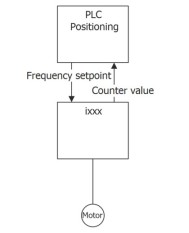
Preconditions
–
The number of motor revolutions is reconstructed from the motor model. For this purpose, the motor control type "Sensorless control (SL PSM) [3]" must be selected and set in 0x2C00 (P300.00).  Sensorless control for synchronous motor (SL-PSM)
 –
The position control must be implemented in the Controller.
Details
The signal source for the position counter is selected in 0x2C49:001 (P711.01). The position counter can count forwards and backwards. The current counter content (actual position) is displayed in 0x2C49:003 (P711.03). After the maximum or minimum value has been reached, an overflow takes place.
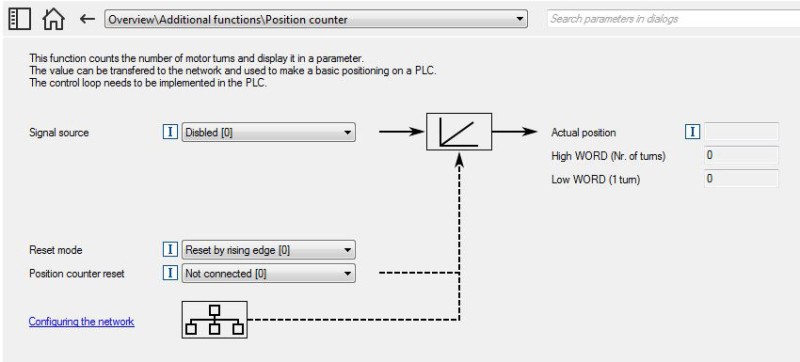
Reset position counter:
–
The position counter is reset when the supply voltage is switched on.
–
The position counter can be reset manually via the "Set position counter" 0x2631:054 (P400.54) function or the NetWordIN1 0x4008:001 (P590.01) data word. For a reset via NetWordIN1, the "Position counter reset [54]" function must be assigned to a bit of the data word. Depending on the selection in 0x2C49:002 (P711.02), the reset can be made either edge-controlled or status-controlled.
Parameter
|
Address
|
Name / setting range / [default setting]
|
Information
|
|
|
0x2631:054
(P400.54)
|
Function list: Set position counter
(Function list: Set pos counter)
|
Assignment of a trigger for the "Set position counter" function.
Trigger = FALSE-TRUE edge: Reset position counter manually.
Trigger = FALSE: no action.
Notes:
–
In 0x2C49:002 (P711.02) it can be selected whether the reset is to be effected edge-controlled (default setting) or status-controlled.
|
|
|
0
|
Not connected
|
No trigger assigned (trigger is constantly FALSE).
|
|
|
0x2C49:001
(P711.01)
|
Position counter: Signal source
(Position counter: Signal source)
–
From version 03.00
|
Selection of the signal source for the position counter.
|
|
|
0
|
Disabled
|
Position counter is deactivated.
|
|
|
5
|
Internal motor model
|
The motor revolutions reconstructed from the internal motor model of the sensorless control (SL PSM) are counted.
–
The counter content will not be updated if the power section is switched off.
–
After restarting the power section, the counting of the last counter content is continued.
|
|
|
0x2C49:002
(P711.02)
|
Position counter: Set position
(Position counter: Set position)
–
From version 03.00
|
Selection if the manual reset of the position counter is to be effected edge-controlled or status-controlled.
|
|
|
0
|
By rising edge
|
||
|
1
|
By signal state TRUE
|
||
|
0x2C49:003
(P711.03)
|
Position counter: Actual position
(Position counter: Actual position)
–
Read only
–
From version 03.00
|
Mappable parameter for providing the current counter content (actual position) via network.
Scaling (applies to every measuring method or encoder resolution):
–
Upper 16 bits: Counted revolutions (0 ... 65535, overflow possible)
–
Lower 16 bits: Current position within the revolution (0 ... 65535)
|
|
 Trigger list