Encoder monitoring
For monitoring the HTL encoder, two monitoring functions are implemented in the inverter firmware:
a.
Encoder signal loss monitoring: Is triggered if a failure of the encoder signal is detected (e. g. due to open circuit or failure of the encoder current supply).
b.
Encoder maximum frequency monitoring: Is triggered if the calculated encoder maximum frequency is beyond the permissible frequency range of the digital inputs.
These monitoring functions are plausibility tests. The hardware circuit of the inverter cannot distinguish whether the motor shaft is blocked or the encoder signal cables are interrupted. Monitoring is restricted to operating points where most likely encoder pulses are to be expected. Another requirement is to avoid false alarms. This especially restricts monitoring at standstill and at low speeds.
Encoder monitoring shows a different behavior for:
Case a) Restrictions if the HTL encoder is set as feedback system for the motor control:
0x2C00 (P300.00) = [2] servo control (SC-ASM)
0x2C00 (P300.00) = [7] V/f characteristic control (VFC closed loop)
In this case, it does not matter whether the HTL encoder is also used as signal source for the "position counter" function.
Case b) The HTL encoder is used as signal source for the "position counter" function 0x2C49:001 (P711.01) and one of the following sensorless motor control modes is set:
0x2C00 (P300.00) = [3] Sensorless control (SL-PSM)
0x2C00 (P300.00) = [4] Sensorless vector control (SLVC)
0x2C00 (P300.00) = [6] V/f characteristic control (VFC open loop)
Conditions
The encoder signal loss monitoring is only active if the HTL encoder
–
is set as feedback system for the motor control or
–
used as signal source for the "Position counter" function.
–
For the encoder signal loss monitoring, the inverter must be enabled and the motor must rotate.
The encoder maximum frequency monitoring is active as soon as the HTL encoder has been configured.
Restrictions
–
The encoder signal loss monitoring does not work while the "DC braking" function is active.
–
The response time of the encoder signal loss monitoring depends on the setting of the encoder increments per revolution in 0x2C42:001 (P341.01).
–
The settings of the speed controller can influence the encoder signal loss monitoring. If the reset time of the speed controller is very low or deactivated, an encoder signal loss cannot be detected at switch-on.
–
Combined with the "Holding brake control" function:
 Holding brake control
–
In order that the encoder signal loss monitoring is not triggered by mistake, monitoring is only activated when the holding brake is released.
–
If Brake closing time 0x2820:002 (P712.02) and Brake opening time 0x2820:003 (P712.03) are not set correctly, the encoder signal loss monitoring can be triggered even though an encoder signal is available.
Holding brake control –
If the configuration of the digital inputs 0x2630:002 (P410.02) is = function [4] low-resolution HTL encoder <= 128 increments, the interruption of the track A (DI3) is not detected.
Case a) Restrictions if the HTL encoder is set as feedback system for the motor control:
–
Monitoring is only active if the output frequency is higher than 1.5 times of the rated slip frequency of the motor. This applies to the setting 0x2630:002 (P410.02) = 1 and 0x2630:002 (P410.02) = 4.
Case b) Restrictions if the HTL encoder is used as signal source for the "Position counter" function (0x2C49:002).
–
Monitoring is only active if the speed [rpm] measured by the encoder is higher than the threshold according to the following table and the signal is lost!
|
Encoder
Increments per revolution
|
0x2630:002 = [1]
Threshold [rpm]
|
0x2630:002 = [4]
Threshold [rpm]
|
|
128
|
117.2
|
468.8
|
|
256
|
58.6
|
58.6
|
|
512
|
29.3
|
117.1
|
|
1024
|
14.6
|
58.6
|
–
A signal loss is not detected if the encoder signals already disappear when the inverter is enabled (zero speed).
Details on encoder signal loss monitoring
The encoder signal loss monitoring distinguishes between the following signal failures:
a.
Complete failure (total absence of the encoder signal, e. g. if the encoder power supply fails)
b.
Only one track has failed (track A or track B)
In order to detect a complete failure (a.), the inverter calculates internally two trigger thresholds for monitoring based on the configuration of the HTL encoder:
1.
Based on the motor data, the rated motor slip frequency is calculated. Display of parameter 0x2C02:004 (P351.04). The minimum output frequency for encoder monitoring is 1.5 * rated motor slip.
2.
The maximum permitted time is calculated in which a new signal edge of the encoder must arrive:
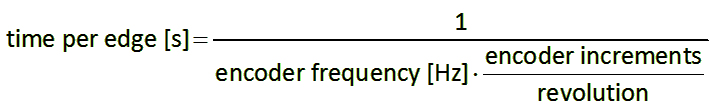
If the real encoder frequency is lower than the calculated minimum output frequency AND if the new signal edge has not arrived within the maximum permitted time, monitoring is triggered.
The complete failure is displayed via the status bit 4 in 0x2C42:007
If only track A or B fails (b.), signals continue to be detected. In this case, however, the sign of the frequency changes with every new signal edge. In order to detect the failure of only one track, an internal counter is increased by 1 every time the sign between two signal edges changes. If the sign is unchanged in two signal edges in a row, the counter is reset. If the counter reaches the counter content "100", monitoring is triggered. The failure of only one track is displayed via the status bit 5 in 0x2C42:007.
Both in case of a complete failure and in case only one track fails, the error message "Encoder open circuit" (error code 29445 | 0x7305) is output. The error response can be selected in 0x2C45 (P342.00).
Details on encoder maximum frequency monitoring
After the HTL encoder has been configured (or if the encoder settings are changed), the inverter internally calculates the maximum possible number of encoder pulses per second (hereinafter referred to as "encoder maximum frequency"):
|
|
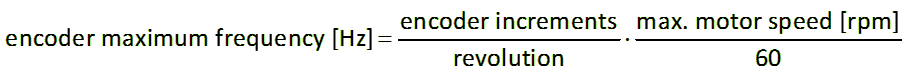
If the calculated encoder maximum frequency is beyond the permissible frequency range of the digital inputs, monitoring is triggered:
–
The status bit 0 in 0x2C42:007 is set to "1".
–
Calculation example 1:
–
Maximum input frequency of the digital inputs = 100 kHz
–
Encoder resolution 0x2C42:001 (P341.01) = 1024 increments/revolution
–
Max. motor speed 0x6080 (P322.00) = 3000 rpm
Result: The encoder maximum frequency monitoring is not triggered because the encoder maximum frequency is within the permissible frequency range of the digital inputs.
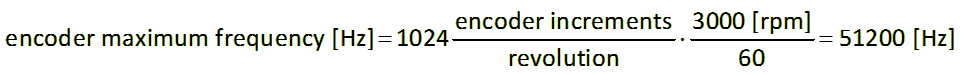
Calculation example 2:
–
Maximum input frequency of the digital inputs = 100 kHz
–
Encoder resolution 0x2C42:001 (P341.01) = 4096 increments/revolution
–
Max. motor speed 0x6080 (P322.00) = 3600 rpm
Result: The encoder maximum frequency monitoring is triggered because the encoder maximum frequency is beyond the permissible frequency range of the digital inputs.
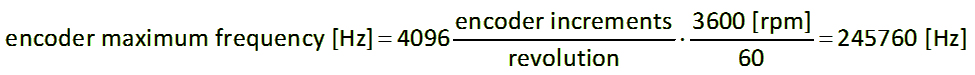
Parameter
|
Address
|
Name / setting range / [default setting]
|
Information
|
|
|
0x2C42:007
|
Encoder settings: Status
–
Read only
–
From version 02.00
|
Bit coded display of the status of encoder monitoring.
Display of the encoder status.
|
|
|
Bit
0
|
Maximum encoder speed reached
|
1 = the calculated encoder maximum frequency is beyond the permissible frequency range of the digital inputs.
|
|
|
Bit
4
|
No signal detected
|
1 = a complete failure of the encoder signals has been detected.
No pulse detected.
|
|
|
Bit
5
|
Encoder track A or B missing
|
1 = a failure of only one track (track A or track B) has been detected.
Weak pulses (one of the tracks A or B is missing).
|
|
|
0x2C45
(P342.00)
|
Motor feedback error response
(Motor feedb. error response)
–
From version 03.00
|
Selection of the response to the triggering of the encoder signal loss monitoring.
The monitoring is only active if the HTL encoder
–
is set as feedback system for the motor control or
–
used as signal source for the "Position counter" function.
|
|
|
0
|
No response
|
||
|
1
|
Warning
|
||
|
3
|
Fault
|
||
 Severity