Stop behavior
In the default setting, the motor is brought to a standstill after a stop command with standard ramp. Alternatively, coasting, ramping down with quick stop ramp or a switch-off positioning can be selected.
Details
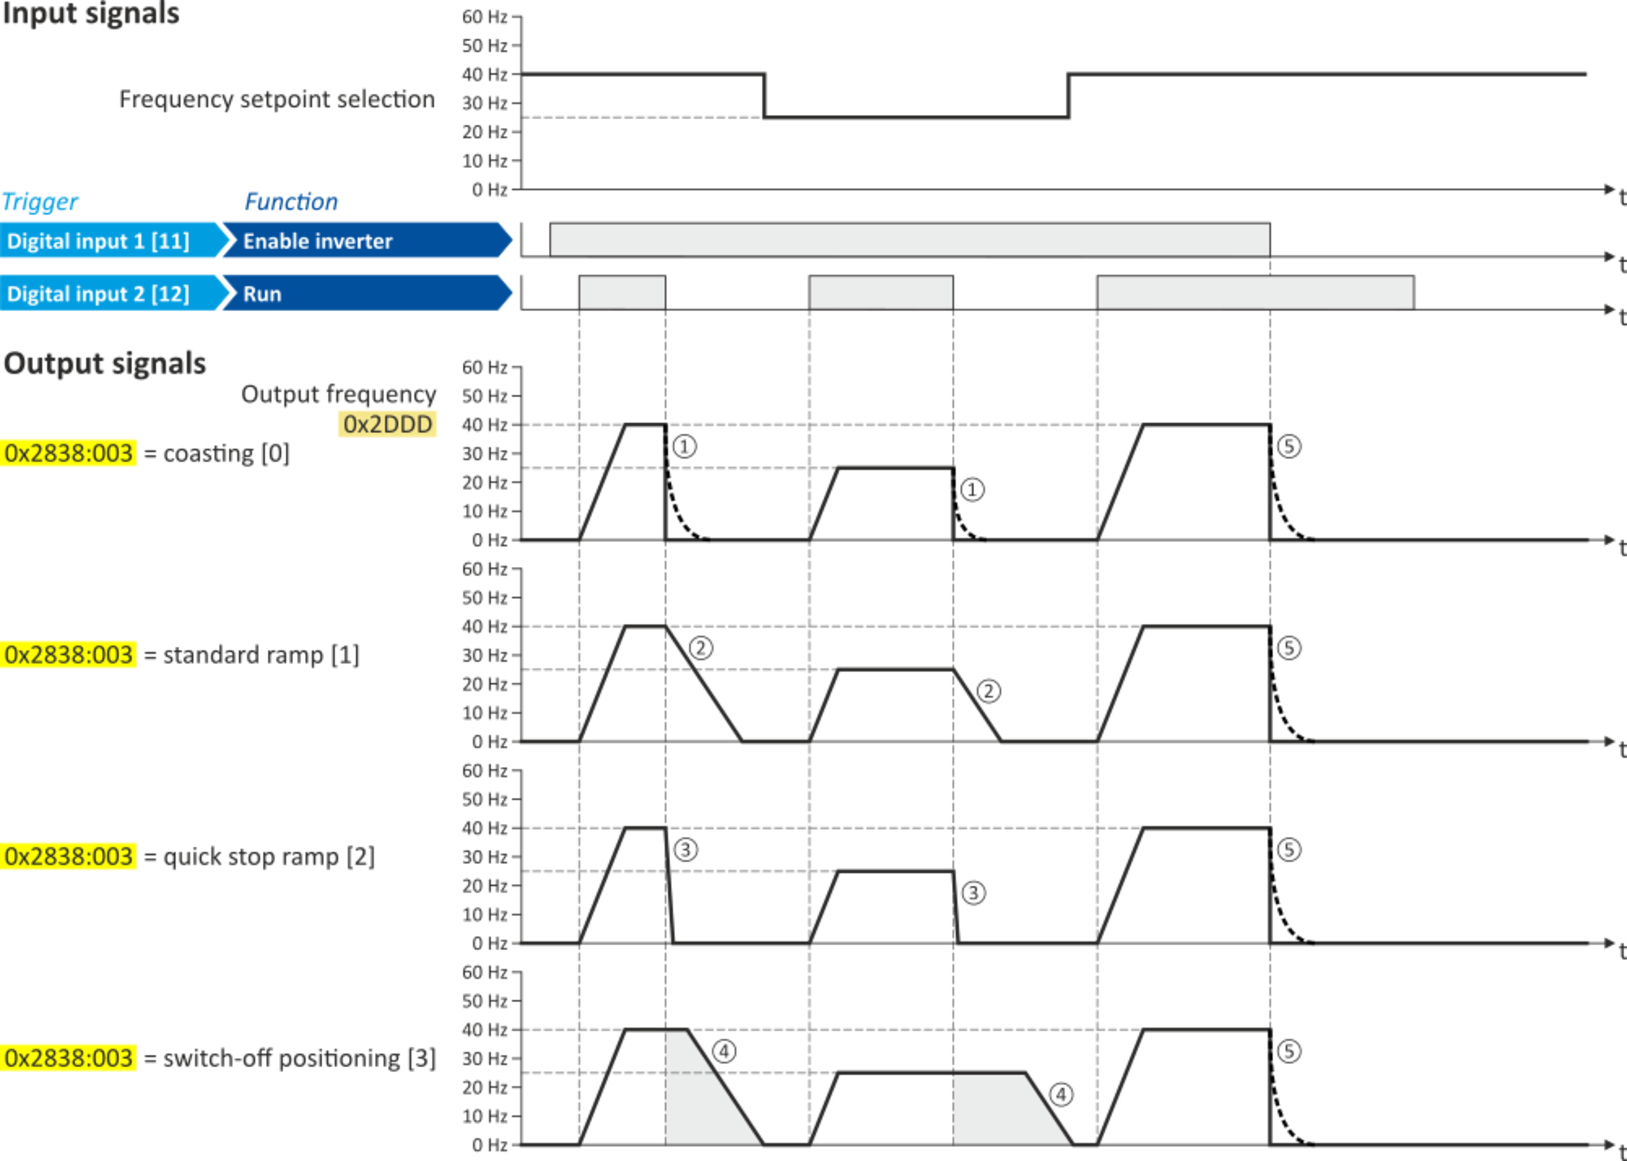
The stop method can be selected in 0x2838:003 (P203.03). The following diagram demonstrates the different stop methods:
|
①
|
Stop method = "Coasting [0]": The motor coasts down.
|
|
②
|
Stop method = "Standard ramp [1]": The motor is brought to standstill with a deceleration time 1 (here: 10 s).
|
|
③
|
Stop method = "Quick stop ramp [2]": The motor is brought to a standstill with the deceleration time for quick stop (here: 1 s).
|
|
④
|
Stop method = "Switch-off positioning [3]": this method is similar to the stop method "Standard ramp". Depending on the current output frequency, however, the inverter delays the beginning of the down-ramping so that the number of motor revolutions until a standstill is reached and thus the stopping position is always relatively constant.
|
|
⑤
|
If "Enable inverter" is set to FALSE, the inverter is disabled. The motor has no torque and coasts to standstill depending on the mass inertia of the machine (irrespective of the set stop method).
|
Parameter
|
Address
|
Name / setting range / [default setting]
|
Information
|
|
|
0x2838:003
(P203.03)
|
Start/stop configuration: Stop method
(Start/stop confg: Stop method)
|
Response after stop command.
|
|
|
0
|
Coasting
|
The motor has no torque (coasts down to standstill).
|
|
|
1
|
Standard ramp
|
The motor is brought to a standstill with deceleration time 1 (or deceleration time 2, if activated).
–
Deceleration time 1 can be set in 0x2918 (P221.00).
–
Deceleration time 2 can be set in 0x291A (P223.00).
|
|
|
2
|
Quick stop ramp
|
The motor is brought to a standstill with the deceleration time set for the "Quick stop" function.
–
Deceleration time for quick stop can be set in 0x291C (P225.00).
–
The "quick stop" function can also be activated manually, for instance via a digital input.
 Flexible I/O configuration of the start, stop and rotating direction commands |
|
|
3
|
Switch-off positioning
|
Is similar to the stop method "Standard ramp [1]". Depending on the current output frequency, however, the inverter delays the beginning of the down-ramping so that the number of motor revolutions until a standstill and thus the stopping position is always relatively constant.
|
|