Change over to ramp 2 during operation
Two different ramps can be parameterised for the frequency setpoint. The change-over to the ramp 2 can be initiated manually or automatically.
Details
For ramp 2, the acceleration time 2 set in 0x2919 (P222.00) and the deceleration time 2 set in 0x291A (P223.00) apply.
The change-over to ramp 2 is effected automatically if the frequency setpoint (absolute value) ≥ auto-changeover threshold 0x291B (P224.00).
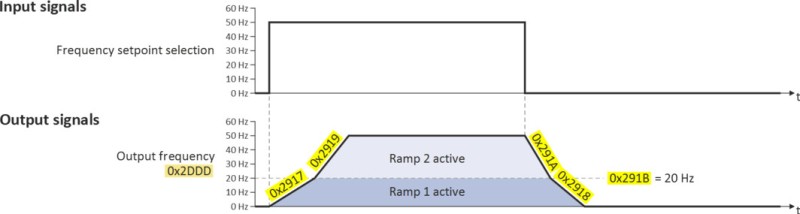
The "Activate ramp 2" 0x2631:039 (P400.39) function is used to manually activate the acceleration time 2 and the deceleration time
2.
2.
Parameter
|
Address
|
Name / setting range / [default setting]
|
Information
|
|
|
0x2919
(P222.00)
|
Acceleration time 2
(Accelerat.time 2)
0.0 ... [5.0] ... 3600.0 s
|
Acceleration time 2 for the operating mode "MS: Velocity mode".
–
The acceleration time set refers to the acceleration from standstill to the maximum frequency set. In the case of a lower setpoint selection, the actual acceleration time is reduced accordingly.
–
The acceleration time 2 is active if the frequency setpoint (absolute value) ≥ auto switching threshold 0x291B (P224.00) or the trigger assigned to the function "Activate ramp 2" in 0x2631:039 (P400.39) = TRUE.
–
The acceleration time 2 is also used for changing the MOP setpoint generated by the "motor potentiometer" function.
–
Setting is not effective in the operating mode 0x6060 (P301.00) = "CiA: Velocity mode (vl) [2]".
|
|
|
0x291A
(P223.00)
|
Deceleration time 2
(Decelerat.time 2)
0.0 ... [5.0] ... 3600.0 s
|
Deceleration time 2 for the operating mode "MS: Velocity mode".
–
The deceleration time set refers to the deceleration from the maximum frequency set to standstill. In the case of a lower actual frequency, the actual deceleration time is reduced accordingly.
–
The deceleration time 2 is active if the frequency setpoint (absolute value) ≥ auto change-over threshold 0x291B (P224.00) or the trigger assigned to the function "Activate ramp 2" in 0x2631:039 (P400.39) = TRUE.
–
The deceleration time 2 is also used for changing the MOP setpoint generated by the "motor potentiometer" function.
–
Setting is not effective in the operating mode 0x6060 (P301.00) = "CiA: Velocity mode (vl) [2]".
|
|
|
0x291B
(P224.00)
|
Auto-changeover threshold of ramp 2
(Ramp 2 thresh.)
0.0 ... [0.0] ... 599.0 Hz
|
Threshold for the automatic change-over to acceleration time 2 and deceleration time 2.
–
The change-over is effected if the frequency setpoint (absolute value) ≥ auto change-over threshold.
–
With the setting 0, the automatic change-over function is deactivated.
|
|
|
0x2631:039
(P400.39)
|
Function list: Activate ramp 2
(Function list: Activ. ramp 2)
|
Assignment of a trigger for the "Activate ramp 2" function.
Trigger = TRUE: activate acceleration time 2 and deceleration time 2 manually.
Trigger = FALSE: no action / deactivate function again.
Notes:
–
If the function is used and the assigned trigger = TRUE, the auto change-over threshold 0x291B (P224.00) for ramp 2 is deactivated.
–
Acceleration time 2 can be set in 0x2919 (P222.00).
–
Deceleration time 2 can be set in 0x291A (P223.00).
|
|
|
0
|
Not connected
|
No trigger assigned (trigger is constantly FALSE).
|
|
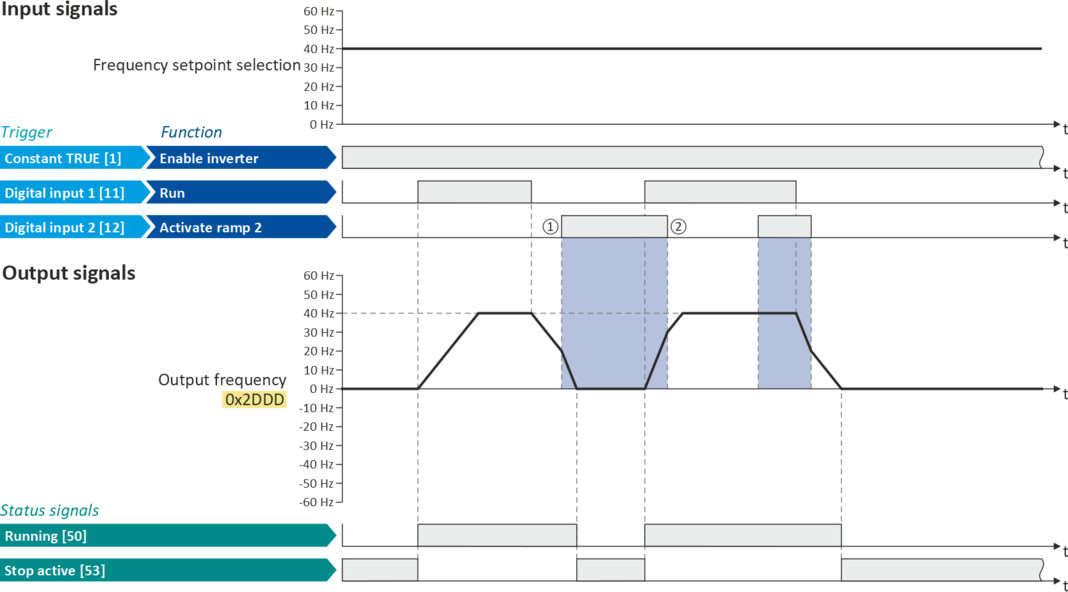
Example for operating mode
–
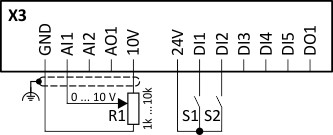
Switch S1 starts the motor in forward direction of rotation. Switch S1 in initial position stops the motor again.
–
Switch S2 activates the acceleration time 2 and deceleration time 2.
|
Connection plan
|
Function
|
|
|
|
Potentiometer R1
|
Frequency setpoint selection
|
|
Switch S1
|
Run
|
|
|
Switch S2
|
Activate ramp 2
|
|
|
Parameter
|
Name
|
Setting for this example
|
|
Enable inverter
|
Constant TRUE [1]
|
|
|
Run
|
Digital input 1 [11]
|
|
|
Reset fault
|
Not connected [0]
|
|
|
Activate ramp 2
|
Digital input 2 [12]
|
|
|
Control selection
|
Flexible I/O configuration [0]
|
|
|
Stop method
|
Standard ramp [1]
|
|
|
Frequency control: Default setpoint source
|
Analog input 1 [2]
|
|
|
Acceleration time 1
|
10.0 s
|
|
|
Deceleration time 1
|
10.0 s
|
|
|
Acceleration time 2
|
5.0 s
|
|
|
Deceleration time 2
|
5.0 s
|
|
The status signals can be assigned to digital outputs.
 Configure digital outputs |
|
|
|
|
|
①
|
Change-over to deceleration time 2 during the deceleration phase.
|
|
②
|
Change-over to acceleration time 1 during the acceleration phase.
|