MC_MoveContinuousRelative
This FB serves to execute a relative positioning. In contrast to the MC_MoveRelative command, the target position is approached with the defined final velocity. If no further motion command is available in the buffer, the axis continues to traverse with the defined final velocity.
|
|
|
|
MC_MoveContinuousRelative |
|
|
|
|
|---|---|---|---|---|---|---|---|
|
AXIS_REF |
- |
|
Axis |
InEndVelocity |
|
- |
BOOL |
|
BOOL |
- |
|
Execute |
Busy |
|
- |
BOOL |
|
BOOL |
- |
|
ContinuousUpdate |
Active |
|
- |
BOOL |
|
LREAL |
- |
|
Distance |
CommandAborted |
|
- |
BOOL |
|
LREAL |
- |
|
EndVelocity |
Error |
|
- |
BOOL |
|
LREAL |
- |
|
Velocity |
ErrorID |
|
- |
L_IE1P_Error |
|
LREAL |
- |
|
Acceleration |
|
|
|
|
|
LREAL |
- |
|
Deceleration |
|
|
|
|
|
LREAL |
- |
|
Jerk |
|
|
|
|
|
MC_BUFFER_MODE |
- |
|
BufferMode |
|
|
|
|
|
|
|
|
|
|
|
|
|
Inputs
|
Name Data type |
Information/possible settings |
|
|---|---|---|
|
Axis |
Transfer of the axis data structure |
|
|
Execute BOOL |
FALSE ä TRUE |
Start positioning. |
|
ContinuousUpdate BOOL |
Continuous acceptance of the profile parameters |
|
|
FALSE |
The profile parameters ( Distance , Velocity , Acceleration , ...) are accepted with a rising edge at Execute . |
|
|
TRUE |
The profile parameters are accepted continuously, i.e. during the execution, the motion profile may change. Note: After the position and final speed ( InEndVelocity = TRUE) have been reached, the profile parameters are not accepted continuously anymore. |
|
|
Distance LREAL |
Distance to be traversed in [unit]
|
|
|
EndVelocity LREAL |
Final velocity in [units/s] for moving to the target position. The final velocity is absolute. This means that the drive moves in a positive direction if the setting is positive and in a negative direction if the setting is negative. |
|
|
Velocity LREAL |
Maximum velocity in [unit/s] for approaching the target position
Special case : Velocity = 0: The default value defined in subindex 40 is used for the velocity. |
|
|
Acceleration LREAL |
Maximum acceleration in [unit/s 2 ] Special case : Acceleration = 0: The default value defined in subindex 41 is used for the acceleration. |
|
|
Deceleration LREAL |
Maximum deceleration in [unit/s 2 ] Special case : Deceleration = 0: The default value defined in subindex 41 is used for the acceleration. |
|
|
Jerk LREAL |
Maximum jerk in [unit/s 3 ] Special case : Jerk = 0: The default value defined in subindex 43 is used for the jerk. |
|
|
BufferMode |
Mode for processing successive motion commands |
|
 Motion axes (AXIS_REF)
Outputs
In the following example, two FB instances of MC_MoveContinuousRelative and one FB instance of MC_MoveRelative are connected in series as a cascade.
- After the respective distance is executed and the final velocity has been reached, the execution of the next instance is started.
- As the last FB in the cascade, the motion command MC_MoveRelative is used instead of MC_MoveContinuousRelative in order that the axis comes to a standstill and does not continue to traverse with the defined final velocity.
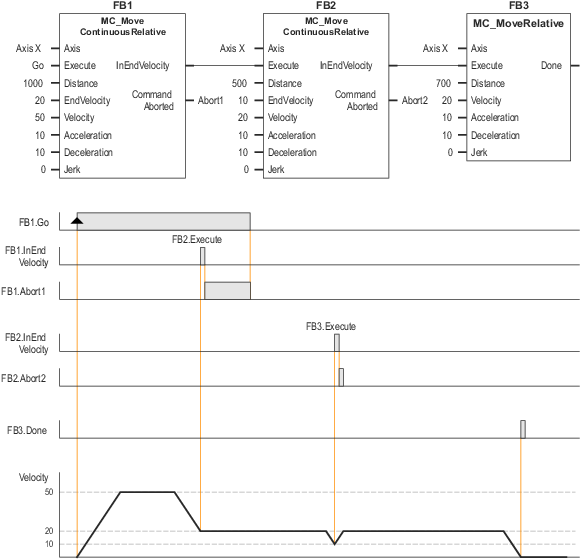
Example: Linking two MC_MoveContinuousRelative commands with a MC_MoveRelative command