Scara_4dof
The "Scara_3dof" axes group describes a horizontal articulated robot with four Cartesian degrees of freedom (X, Y, Z and C).
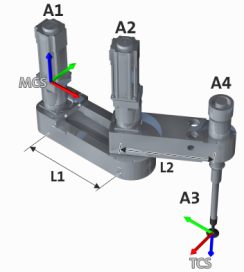
Degrees of freedom (dof)
|
Degrees of freedom (dof) |
Translation |
Rotation |
|---|---|---|
|
Drives |
A3 |
A1, A2, A4 |
|
Tool |
x, y, z |
C |
MCS position
- Z axis is aligned with the first rotary axis.
- When angle setting A1 = 0 °, x axis points towards A2.
- Y axis results from the Cartesian coordinate system.
TCS position, relatively to the MCS
-
Z axis in direction of impact of the robot
 Aligned opposite to z
MCS
.
- In zero position, x TCS and x MCS are parallel.
- In zero position, the origin is z MCS = 0.
Zero position of the drives
- In the zero position of the drives, the robot is in extended position.
- Both robot elements are aligned along the x MCS axis.
- The end effector (TCS) is on z MCS = 0.
Configuration
The angular setting of the Scara_4dof kinematics is (without considering the axis limitations) ambiguous for every required target position in the workspace (right and left projection).
The axes group property Configuration (only read access) is used as follows:
|
<axes group instance>.Configuration[1] := {-1, 0, 1}
|
|
Characteristic |
Value |
Meaning |
|---|---|---|
|
Configuration[1] |
-1 |
Left projection (A2 > 0 °) |
|
0 |
Singular joint setting (A2 = 0 °) |
|
|
1 |
Right projection (A2 < 0 °) |
|
Comments on configuration |
|
|---|---|
|
Continuous path movements |
In case of continuous path movements, the configuration cannot be changed.
FBs for continuous path movements: |
|
Point-to-point movements |
In case of point-to-point movements, the configuration can be changed.
FBs for point-to-point movements: |
|
Singularities |
The singular setting A2 = 0 ° can be exclusively approached and left via the FBs MC_MoveDirectAbsolute / MC_MoveDirectRelative and single-axis movements of the drives. Linear, circular and single-axis movements on the main axes x, y, z cannot approach this position. |
Parameter
A complete list of all kinematics-independent parameters can be found in the section
 Short overview of all parameters
Arm length L1 (index offset 3, subindex 2)
|
Length of element 1 (L1)
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||


Arm length L2 (index offset 3, subindex 3)
|
Length of element 2 (L2)
|
|||||||||||
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
mm |
2147483647 |
0 mm |
||||||||
|
|
FLOAT_64 |
||||||||||
Coulomb friction A1 (index offset 3, subindex 51)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm |
2147483647 |
0 Nm |
||||||||
|
|
FLOAT_64 |
||||||||||
Coulomb friction A2 (index offset 3, subindex 52)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm |
2147483647 |
0 Nm |
||||||||
|
|
FLOAT_64 |
||||||||||
Coulomb friction A3 (index offset 3, subindex 53)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm |
2147483647 |
0 Nm |
||||||||
|
|
FLOAT_64 |
||||||||||
Coulomb friction A4 (index offset 3, subindex 54)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm |
2147483647 |
0 Nm |
||||||||
|
|
FLOAT_64 |
||||||||||
Viscous friction A1 (index offset 3, subindex 57)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm/(rad/s) |
2147483647 |
0 Nm/(rad/s) |
||||||||
|
|
FLOAT_64 |
||||||||||
Viscous friction A2 (index offset 3, subindex 58)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm/(rad/s) |
2147483647 |
0 Nm/(rad/s) |
||||||||
|
|
FLOAT_64 |
||||||||||
Viscous friction A3 (index offset 3, subindex 59)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm/(rad/s) |
2147483647 |
0 Nm/(rad/s) |
||||||||
|
|
FLOAT_64 |
||||||||||
Viscous friction A4 (index offset 3, subindex 60)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
Nm/(rad/s) |
2147483647 |
0 Nm/(rad/s) |
||||||||
|
|
FLOAT_64 |
||||||||||
Gravitation x (index offset 3, subindex 71)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
-10 |
m/s² |
10 |
0 m/s² |
||||||||
|
|
FLOAT_64 |
||||||||||
Gravitation y (index offset 3, subindex 72)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
-10 |
m/s² |
10 |
0 m/s² |
||||||||
|
|
FLOAT_64 |
||||||||||
Gravitation z (index offset 3, subindex 73)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
-10 |
m/s² |
10 |
-9.81 m/s² |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter1 (index offset 3, subindex 74)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter2 (index offset 3, subindex 75)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter3 (index offset 3, subindex 76)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter4 (index offset 3, subindex 77)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter5 (index offset 3, subindex 78)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter6 (index offset 3, subindex 79)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter7 (index offset 3, subindex 80)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter8 (index offset 3, subindex 81)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter9 (index offset 3, subindex 82)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
Torque feedforward control: minimum parameter10 (index offset 3, subindex 83)
|
Setting range (min. value | unit | max. value) |
Lenze setting |
||||||||||
|
0 |
|
2147483647 |
0 |
||||||||
|
|
FLOAT_64 |
||||||||||
A minimal dynamic parameter describes a mathematical grouping that may comprise several physical masses, mass inertias and geometric lengths. Together, these result in a readily identifiable parameter set and a time-efficient calculation rule for feedforward control.
For a description of the variables (Inertia<1 ... 4>, Mass<1 ... 4> etc.) and their reference coordinates, refer to the FB L_MK4P_DynamicParScara_4dof .

|
Note!
In contrast to the FB L_MK4P_DynamicParScara_4dof , the values in the following parameters are expressed in SI units [kg], [m] and [kgm²]. |
|
MinimalDynamicParameter 5 := Mass2 * xDistCenterOfMass2 + Mass3 * xDistCenterOfMass3 |
|
MinimalDynamicParameter 6 := Mass2 * yDistCenterOfMass2 + Mass3 * yDistCenterOfMass3 |
|
MinimalDynamicParameter 7 := Mass3 + Mass4 |
|
MinimalDynamicParameter 8 := lnertia4 |
|
MinimalDynamicParameter 9 := Mass4 * xDistCenterOfMass4 |
|
MinimalDynamicParameter 10 := Mass4 * yDistCenterOfMass4 |
Related topics
Traversing ranges of connected axes
Considering differential drives