Motor torque monitoring
This function limits the motor torque during operation.
Preconditions
The motor torque monitoring can only be used for the following motor control types with speed controller:
–
Sensorless control (SL PSM)
–
Sensorless vector control (SLVC)
Details
This function sets the internal status signal "Torque limit reached [79]" = TRUE when the maximum possible torque has been reached.
The limits of the monitoring function are selected via 0x2949:001 (P337.01) (positive torque limit) and 0x2949:002 (P337.02) (negative torque limit). The actual limits can be seen in 0x2949:003 (P337.03) (actual positive torque limit), 0x2949:004 (P337.04) (actual negative torque limit).
–
The status signal is set irrespective of the response 0x2D67:001 (P329.01) and the delay time 0x2D67:002 (P329.02) set for this monitoring.
–
The status signal can be used by the user to
–
activate certain functions.  Flexible I/O configuration
 –
set a digital output. Configure digital outputs
Configure digital outputs –
set a bit of the NetWordOUT1 mappable data word. Motor speed monitoring
Motor speed monitoring 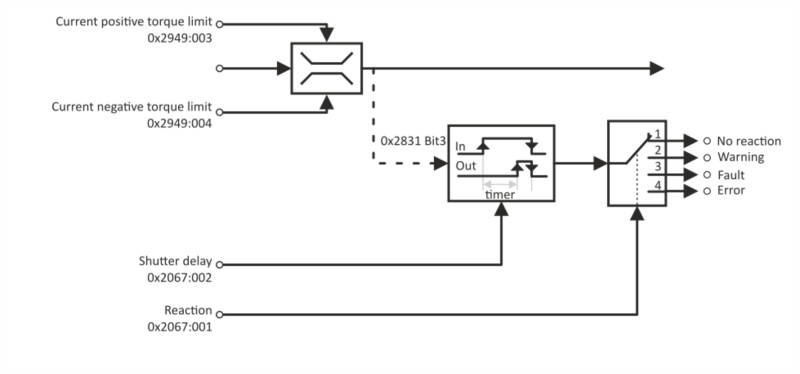
Parameter
|
Address
|
Name / setting range / [default setting]
|
Information
|
|
|
0x2D67:001
(P329.01)
|
Maximum torque monitoring: Response
(MaxTrq.Monitor: Response)
–
From version 02.00
|
Selection of response to reaching the maximum possible torque.
–
The selected response takes place if the status signal "Torque limit reached [79]" = TRUE and the deceleration time set in 0x2D67:002 (P329.02) has elapsed.
|
|
|
0
|
No response
|
||
|
1
|
Warning
|
||
|
2
|
Trouble
|
||
|
3
|
Fault
|
||
|
0x2D67:002
(P329.02)
|
Maximum torque monitoring: Triggering delay
(MaxTrq.Monitor: Triggering delay)
0.000 ... [0.000] ... 10.000 s
–
From version 02.00
|
Optional setting of a deceleration for triggering the response selected in 0x2D67:001 (P329.01).
Typical application:
–
The motor should be driven at the torque limit for a short time without triggering the selected response.
–
Only after a longer operation (> set deceleration) at the torque limit, the selected response is to take place.
|
|
|
0x6072
(P326.00)
|
Max. torque
(Max. torque)
0.0 ... [250.0] ... 3000.0 %
–
From version 02.00
|
Symmetrical selection of the maximum permissible torque.
–
100 % = Rated motor torque 0x6076 (P325.00)
–
This parameter serves to implement a static and bipolar torque limitation. This can be used, for instance, as overload protection of the mechanical transmission path/elements starting at the motor shaft.
–
This limitation acts irrespective of the torque limitations acting in unipolar mode that are set in 0x60E0 and 0x60E1.
|
|
 Severity